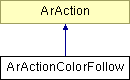
#include <ArActionColorFollow.h>
Inheritance diagram for ArActionColorFollow:
Public Types | |
| enum | LocationState { LEFT, RIGHT, CENTER } |
| enum | MoveState { FOLLOWING, ACQUIRING, STOPPED } |
| enum | TargetState { NO_TARGET, TARGET } |
Public Member Functions | |
| ArActionColorFollow (const char *name, ArACTS_1_2 *acts, ArPTZ *camera, double speed=200, int width=160, int height=120) | |
| virtual ArActionDesired * | fire (ArActionDesired currentDesired) |
| bool | getAcquire () |
| bool | getBlob () |
| int | getChannel () |
| virtual const ArActionDesired * | getDesired (void) const |
| virtual ArActionDesired * | getDesired (void) |
| bool | getMovement () |
| void | setAcquire (bool acquire) |
| void | setCamera (ArPTZ *camera) |
| bool | setChannel (int channel) |
| void | startMovement (void) |
| void | stopMovement (void) |
Protected Attributes | |
| bool | killMovement |
| bool | myAcquire |
| ArACTS_1_2 * | myActs |
| ArPTZ * | myCamera |
| int | myChannel |
| ArActionDesired | myDesired |
| int | myHeight |
| ArTime | myLastSeen |
| LocationState | myLocation |
| int | myMaxTime |
| MoveState | myMove |
| double | mySpeed |
| TargetState | myState |
| int | myWidth |
 1.4.2