Selected Research Topics
Below, you'll find some highlights of the past and present research topics that I've worked on.
MIDI 2.0 Musical Instruments

The Shetu MIDI 2.0 controller is the first MIDI 2.0 instrument developed in an academic setting. This is a collaborative project within the Designing Sound Futures initiative.
Pinball Machines
for Hands-on Experience with Commercial Mechatronics Systems
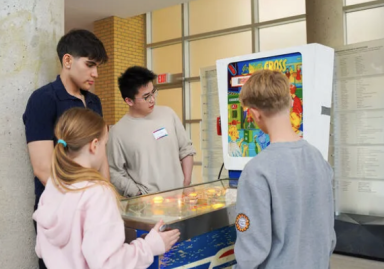
Pinball machines are incredible, practical real-world examples of mechatronic design. My students and I are updating vintage pinball machines using modern hardware elements to expose them to the realities of electro-mechanical engineering design.
Pedagogy: Active and Engaged Teaching in Large Classrooms assignments

At York University I am one of a handful of professors who enjoy and succeed at teaching in large classroom settings or 200 to 500 students. From flipped classes to hands-on isometric drawing exercises I work to make the learning experience in my classrooms engaging, meaningful and relevant. An example publication is Re-engaging Students by Teaching from the Middle and Back of a 500-seat Lecture Hall or my blog post to find out more.
Pedagogy: Automated Exercise and Test Feedback
"A Teacher's Experience with Virtual Programming Lab ". At York University I work with staff and faculty on the development of responsive and secure assessment technologies through our eClass LMS and "Lab Test Mode" infrastructure.
Cervix Phantoms
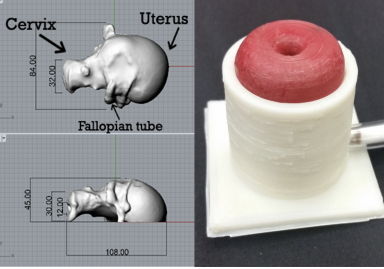
In collaboration with Midwifery at TMU, as well as the McMaster University Hospital and McMaster Department of Obstetrics and Gynecology, we developed a series of robots and simulations to study variable compliance cervix phantoms. Two example videos include this 3D-printed inflatable cervix and this Latex dilation simulator. This is Jung S. Kim's thesis and Michelle Luk's thesis.
Sports Bra Testing Robot

In an NSERC-funded project, we worked with activewear apparel company, Knix, to develop a test platform for their line of sports bras. (Video)
Robot Leg Design
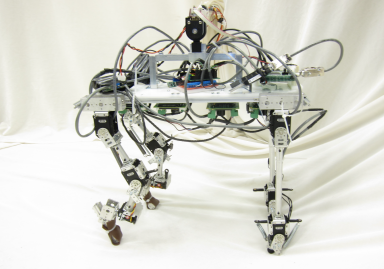
At TMU, my students worked on leg designs and energetics analyses for bipedal and quadrupedal robots. The GARP-5 robot was developed in partnership with EU collaborators in the FP7 Locomorph project.
Toe-walking Robots

During my post-doc at the University of Jena in Germany, I worked on bipedal walking robots, with a special focus on toe-walking.
Galloping Robots

During my PhD work at McGill University I worked on the world's first two galloping robots, Scout II and PAW.
Seismic Surveying and Defence Robots

In the late 1990s I worked on the Polar Bear robot, a 400kg hydraulically-actuated semi-autonomous ground vehicle. The project was initially a student competition robot at the IGVC and, later, a NSERC-funded project with the Department of National Defence and Schlumberger Geco-Prakla. Videos: Overview of Polar Bear and adaptation as mobile target at a firing range near Suffield Alberta.